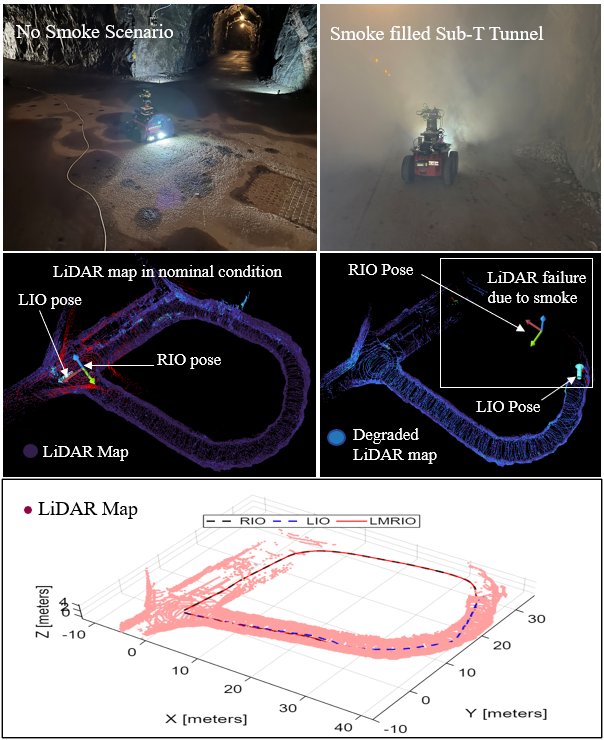
When LiDAR Fades, Radar Takes Over: LiDAR Reliability-Aware Adaptive Localization Under Airborne Obscurants
作者:Moumita Mukherjee, Avijit Banerjee, Anton Koval, George Nikolakopoulo · 单位:and in part by the Swedish Department of Energy and LKAB through the Sustainable, Underground Mining (SUM) Academy Programme project “Autonomous Drones for, Underground Mining Operations.” † † thanks: The authors are with the Robotics and AI Group, Department of Computer, Electrical and Space Engineering, Luleå University of Technology · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-12