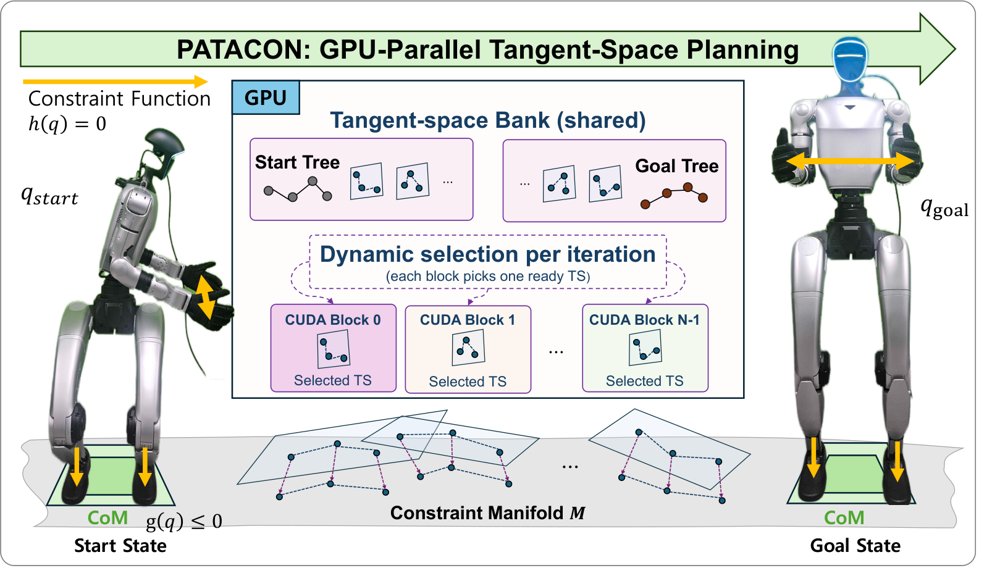
PATACON: GPU-Parallel Tangent-Bundle RRT-Connect for Constrained Motion Planning
作者:Gahyun Oh, Junho An, Suhyun Jeon, Suhan Park · 单位:Department of Robotics, Kwangwoon University, Seoul, Republic of Korea., Department of Intelligence and Information, Graduate School of Convergence Science and Technology, Seoul National University, Republic of Korea. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-12