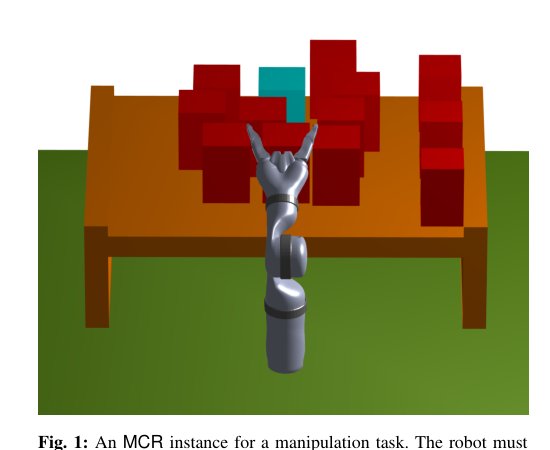
Graph-Based Heuristics for Minimum Constraint Removal in Cluttered Robot Motion Planning
作者:Antony Thomas, Fulvio Mastrogiovanni, Marco Baglietto · 单位:Robotics Research Center, IIIT Hyderabad, 500032, Hyderabad, India., Department of Informatics, Bioengineering, Robotics, and Systems, Engineering, University of Genoa, 16145, Genoa, Italy. Emails: ful-, available [23], with n denoting the number of graph vertices., vertices and uses obstacle labels shared by the two search, denote its obstacle label, that is, the set of obstacles inter-, We assume that G is available, and its construction from a, graph labels represent configuration space obstacles induced · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-12