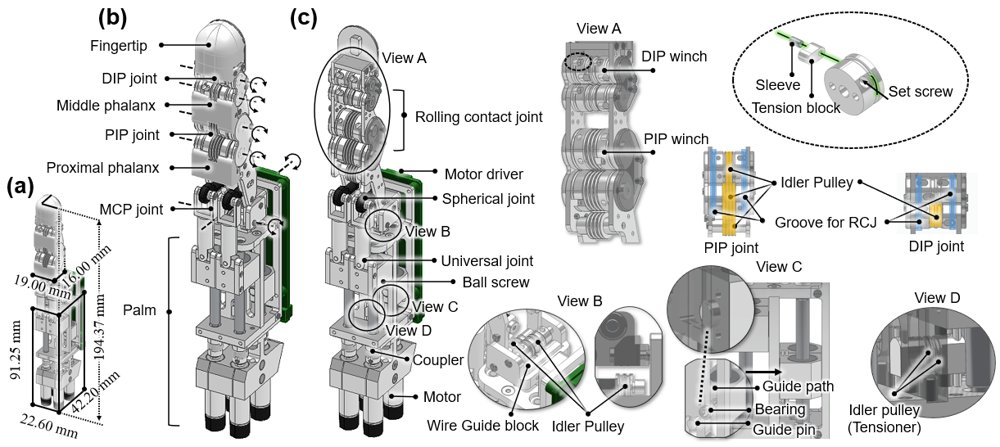
Design of a Fully Actuated 4-DOF Robotic Finger With Joint-Specific Hybrid Remote Actuation
作者:Hyojae Kang, Hyun-mok Jung, Joonho Lee, Dongil Park, Hyunmin Do, Jongwoo Park, Jeongdo Ahn · 单位:Advanced Robotics Research Center, Korea Institute of Machinery & Materials (KIMM), Mechanical Engineering, University of Science & Technology (UST) * Co-Corresponding author · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-08