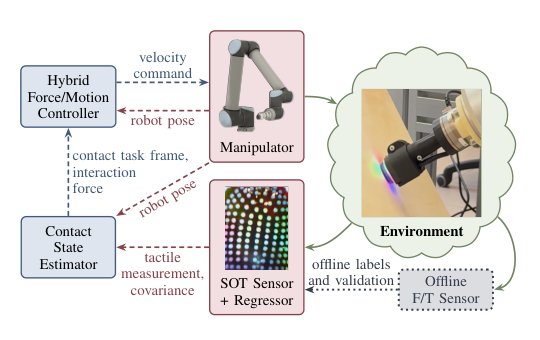
Tactile Reconstruction of Contact Task Frames and Forces for Hybrid Force/Motion Control
作者:Antonio Rapuano, Simone Orelli, Barbara Bazzana, Antonio Franchi, Alessandro De Luca · 单位:labeling acquisition procedure, in which a manipulator imposes, offline to provide ground-truth labels. The tactile measurement is, inspection, service robotics, and human-robot collaboration., Department, University, Engineering, Mathematics and Computer Science, University of Twente, offline labels, When such sensors are unavailable, external wrenches, human-robot collaboration tasks [7]. However, residual meth-, information about the contact that is not directly available from, Force regression methods are also available that estimate, used only offline as ground truth to construct training labels · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-08