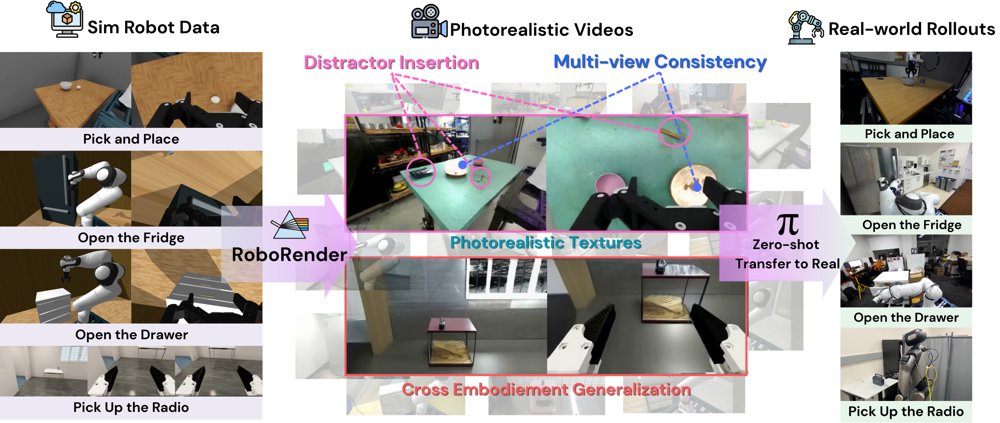
作者:Huang Huang, Wensi Ai, Ziyu Chen, Youhui Wang, Zijian Du, Yang Liu, Jiaolong Yang, Li Fei-Fei, Jiajun Wu · 单位:Stanford University, simulator geometry, robot motion, and action labels while, retaining simulator geometry and action labels, making, grounded, controllable, and embodiment-aware video, Simulation enables scalable robot data generation, but, dynamics, and action labels, while using a generative video, RGB videos. This approach combines the scalability and, grounded dynamics and action labels. Other works add, grounded dynamics, simulator-provided action labels, multi- · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-08
点击后会加入生成队列