Belief-Space Planning with Planner-Conditioned Estimator Error under Intermittent Observations
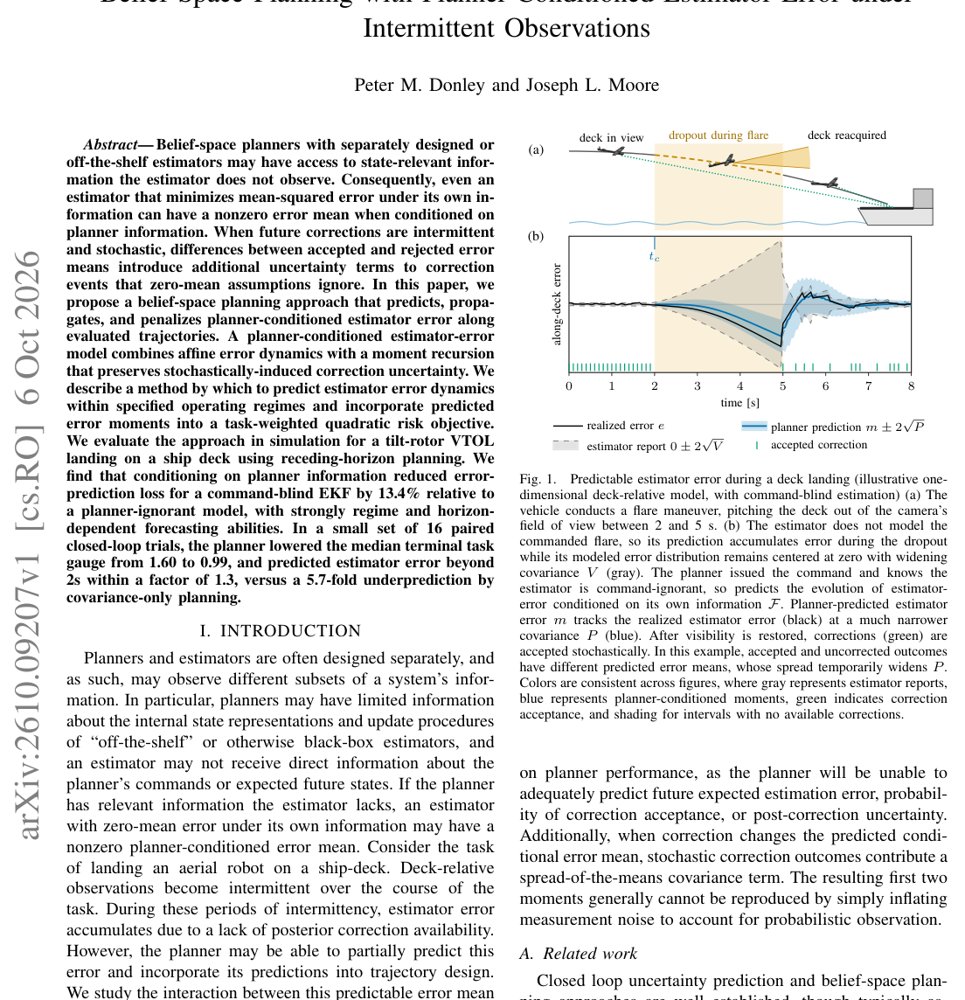
作者:Peter M. Donley, Joseph L. Moore · 单位:accumulates due to a lack of posterior correction availability., and the stochastic availability of future corrections., University, School, while its modeled error distribution remains centered at zero with widening, acceptance, and shading for intervals with no available corrections., planning model [1], [2]. This model uncertainty is centered, probability that usable corrections will be available to the, information available internally to the estimator at time k., The information available to the planner is · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-08