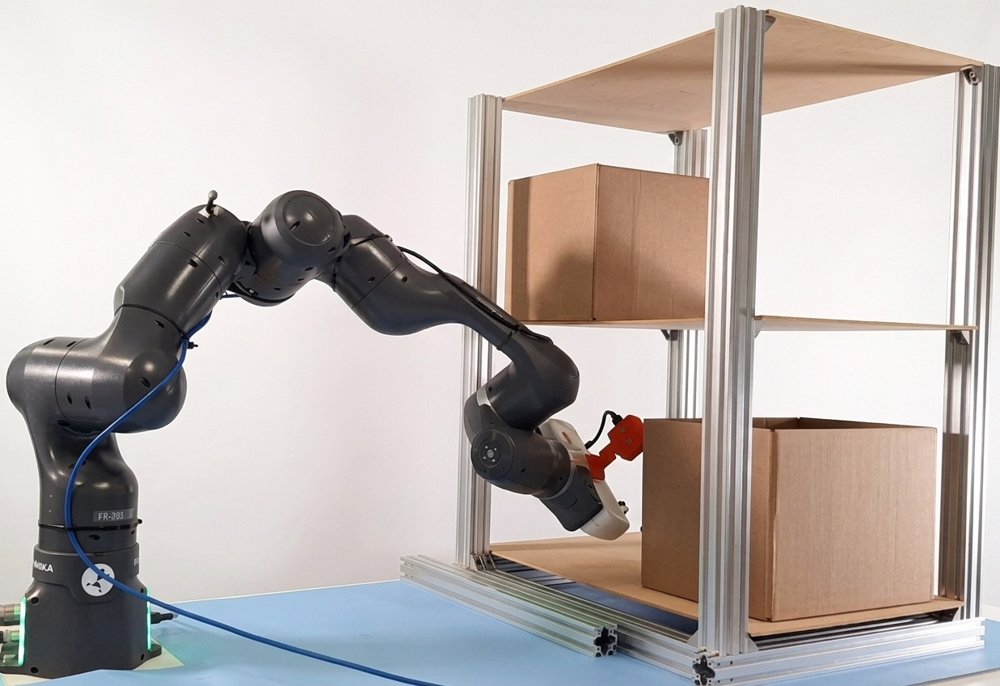
Reactive Exploration of Unknown Environments for Redundant Robots using Virtual Model Control
作者:Alessio Canzolino, Omar Faris, Alessandro De Blasi, Fulvio Forni · 单位:Department of Electrical, Electronic, and Information Engineering “Guglielmo Marconi”, University of Bologna, Italy, Department of Engineering, University of Cambridge, UK. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07