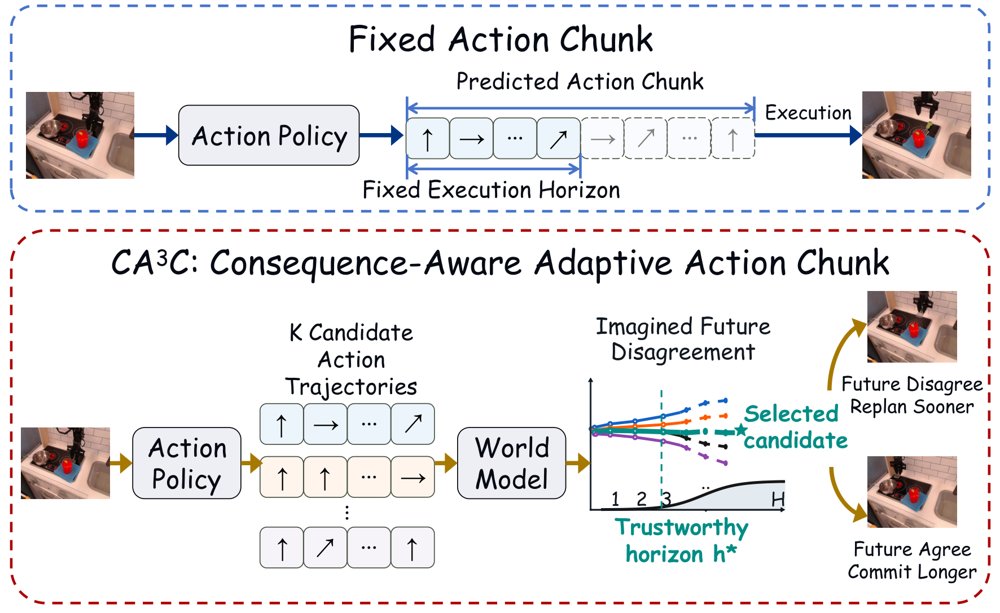
Commit While Futures Agree: Consequence-Aware Adaptive Action Chunking for Robot Manipulation
作者:Yuyan Li, Yujia Wang, Yusong Huang, Junjie Yang, Yanggang Sheng, Ziyi Shi, Wenpeng Xu, Xiaoyang Zhou, Haoang Li, Hongliang Lu, Xinhu Zheng · 单位:The Hong Kong University of Science and Technology (Guangzhou), Victoria University of Wellington, The Hong Kong University of Science and Technology, Southern University of Science and Technology · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07