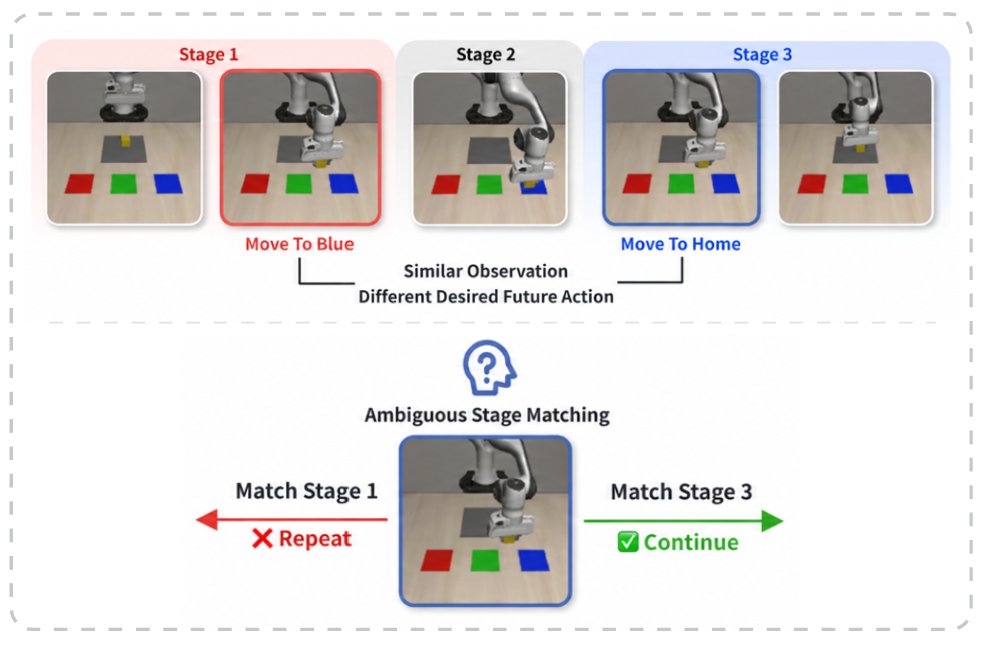
PACE: Stage-Consistent Long-Horizon Robot Manipulation via Progress-Aligned Context for Execution
作者:Yenan Chen, Junjie Shi, Lu Chen, Zhongxiang Zhou, Rong Xiong · 单位:All authors are with the College of Control Science and Engineering, Zhejiang University, Hangzhou 310027, China. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07