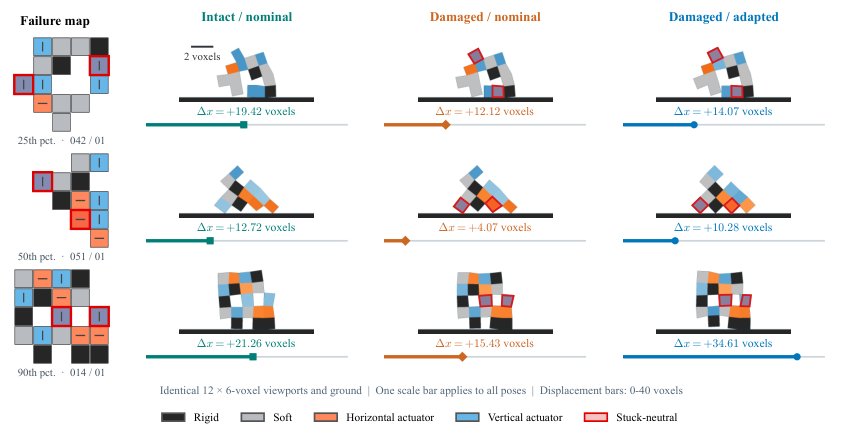
Nine Trials to Recover: A Reproducible Benchmark for Repertoire-Free Soft-Robot Damage Adaptation
作者:Siyuan Zhang · 单位:Siyuan Zhang is with the Robotics Department, University of Michigan, Ann Arbor, MI, USA. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07