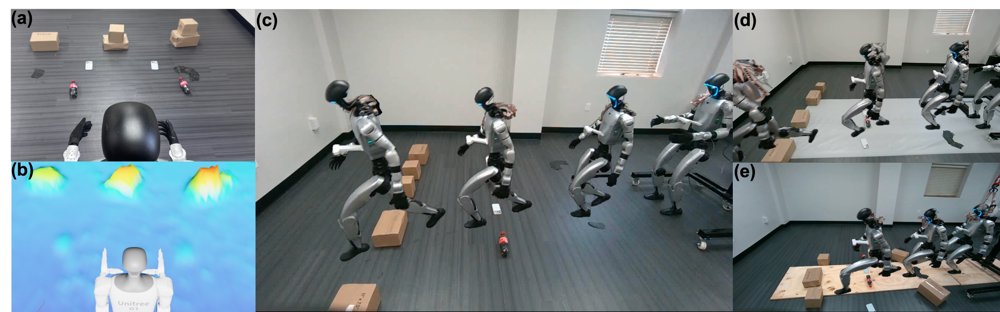
What the Elevation Map Cannot See: Semantic-Aware Locomotion and Execution-Aware Navigation for Humanoid Robot
作者:Shunyu Yao, Songyang Liu, Dinghao Chen, Yuanyuan Lei, Shuai Li · 单位:Engineering School of Sustainable Infrastructure & Environment, University of Florida, Gainesville, FL 32611, USA, Department of Computer & Information Science & Engineering · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07