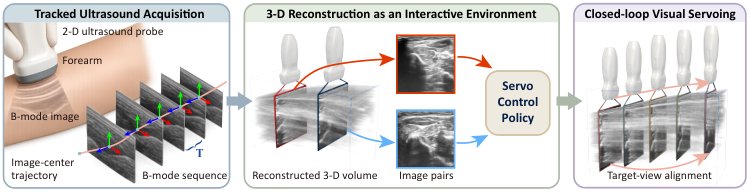
Recon2Servo: Robotic Ultrasound Visual Servoing via Learned Image-to-Motion Inference
作者:Yameng Zhang, Pei Liu, Dianye Huang, Yizhao Qian, Zhongyu Chen, Xiangyu Chu, K. W. Samuel Au, Zhongliang Jiang · 单位:Department of Mechanical Engineering, The University of Hong Kong, Hong Kong SAR., Department of Mechanical and Automation Engineering, The Chinese University of Hong Kong, Hong Kong SAR., School of Computation, Information and Technology, Technical University of Munich, Germany., Department of Electronic Engineering, The Chinese University of Hong Kong, Hong Kong SAR., School of Optometry, Hong Kong Polytechnic University, Hong Kong SAR. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06