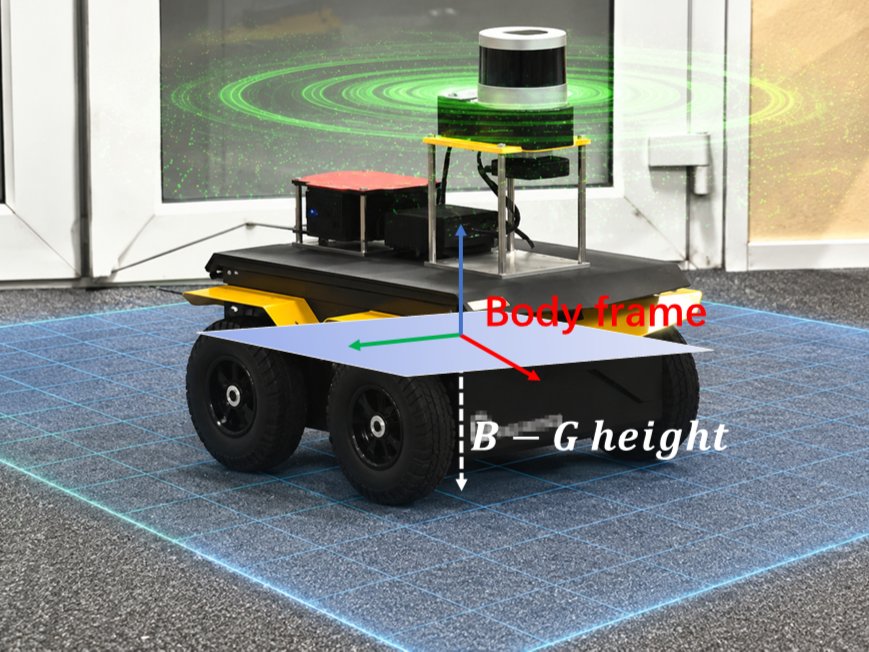
GR-LIO: A Local Ground-Aware LiDAR-Inertial Odometry System Using Body-to-Ground Height
作者:Zhixin Zhang, Yang Song, Liang Zhao, Nathan Shankar, Barry Lennox, Pawel Ladosz · 单位:† † thanks: This work was partially funded by the Robotics and AI Collaboration (RAICo). (Corresponding author: Pawel Ladosz) · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06