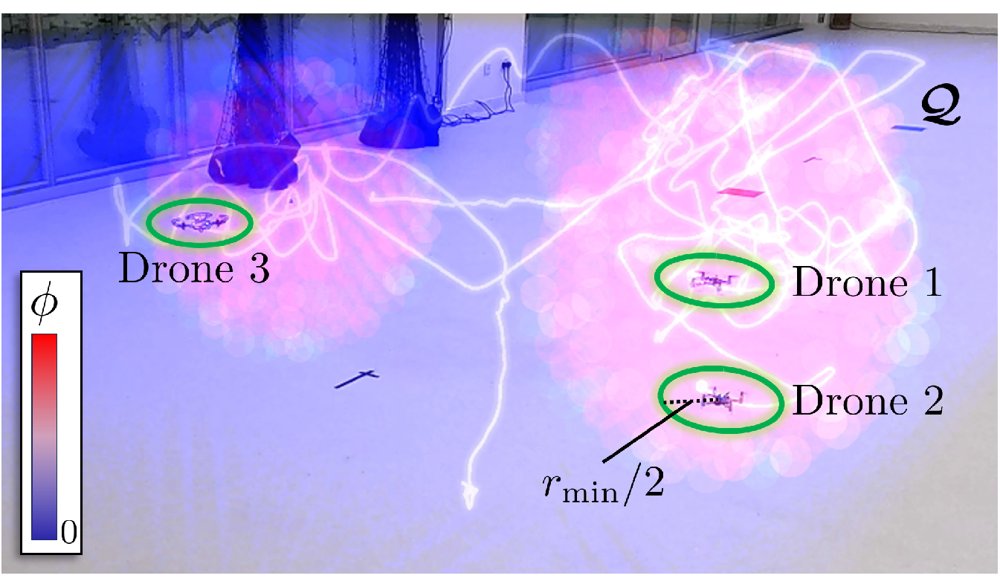
Safe Ergodic Control for Multi-Robot Systems via Quadratic Programming
作者:Yo Toyomoto, Mohamed Elobaid, Bryce L. Ferguson, Alberto Quattrini Li, Shinkyu Park · 单位:† † thanks: ⋆ This work was supported by funding from King Abdullah University of Science and Technology (KAUST) and the Dartmouth Initiative for Middle East Exchange (DIMEX). · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06