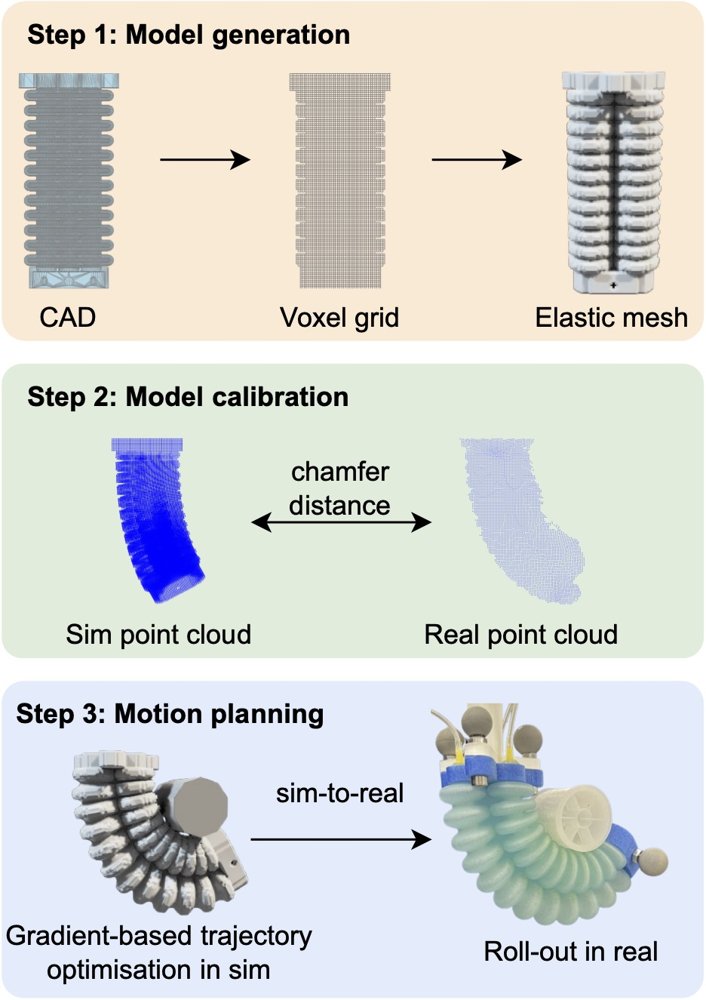
An End-to-End Framework for Modelling Pneumatic Soft Robots Based on Differentiable Finite Element Methods
作者:Shaohong Zhong, Yao Yao, Perla Maiolino, Ingmar Posner · 单位:Oxford Robotics Institute, Department of Engineering Science, University of Oxford, OX1 3PJ Oxford, U.K · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06