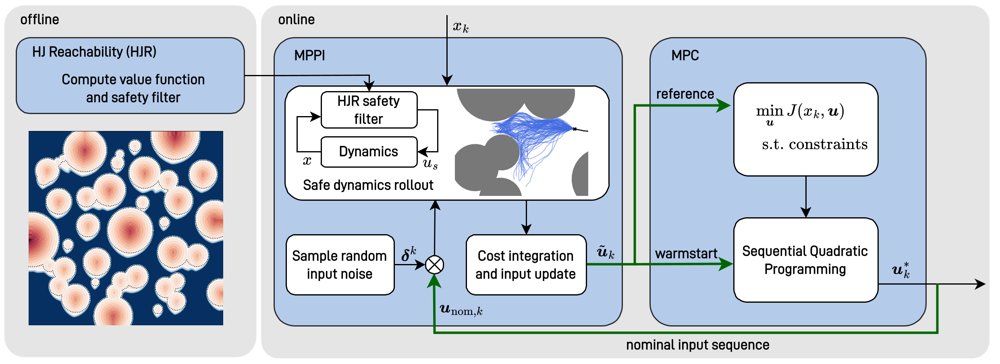
Reachability-Guided Sequential Quadratic Programming-Guarded Model Predictive Path Integral for Safe Nonlinear Predictive Control
作者:Alexandre Didier, Jason J. Choi, Namhoon Cho, Claire J. Tomlin, Melanie N. Zeilinger · 单位:Electrical and Computer Engineering Department, University of California, Los Angeles, CA 90095, USA., Department of Aerospace Engineering, Seoul National University, Seoul 08826, Republic of Korea., Department of Electrical Engineering and Computer Sciences, University of California, Berkeley, CA 94704, USA. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06