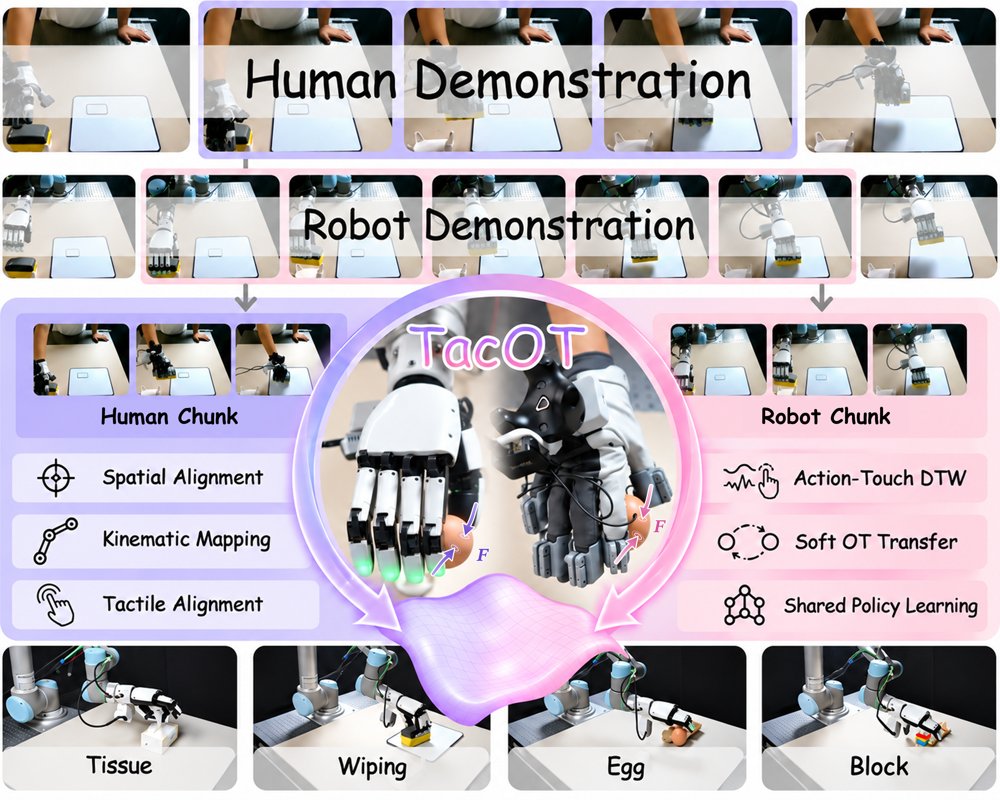
作者:Xingting Li, Yifan Han, Zijian Lin, Wei Hou, Chuqiao Lyu, Shoujie Li, Wenbo Ding · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-06
点击后会加入生成队列