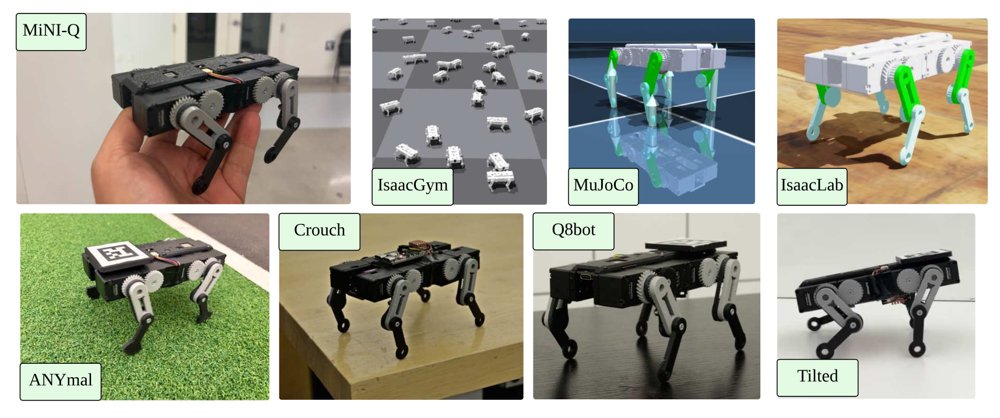
Around the World: Unified Learned Locomotion on a 270 g Continuous-Rotation Quadruped
作者:Arturo Flores Alvarez, Nathan Lintu, Dennis Hong · 单位:† † thanks: All authors are with the Robotics and Mechanisms Laboratory, (RoMeLa), University of California, Los Angeles (UCLA). · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-05