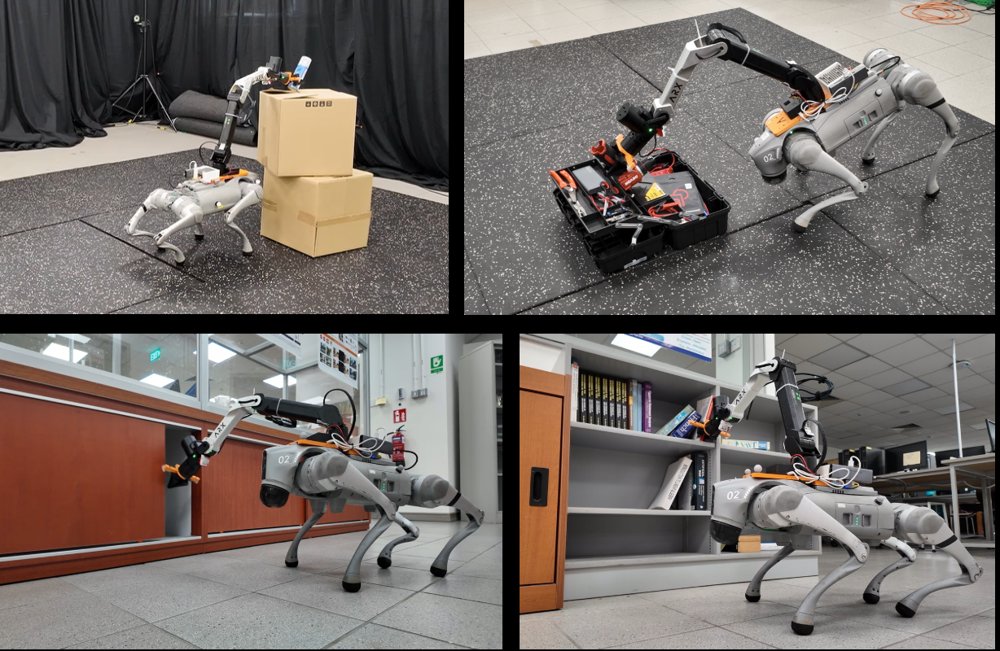
ReCo: Response-Consistent Locomotion with Policy-Aware MPC for Legged Manipulation
作者:Kuankuan Sima, Yichao Gao, Chenxi Gu, Kefan Zhao, Lin Zhao · 单位:Chenxi Gu and Kefan Zhao are with the Department of Mechanical Engineering, National University of Singapore, Singapore 119077, Singapore., National University of Singapore · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-02