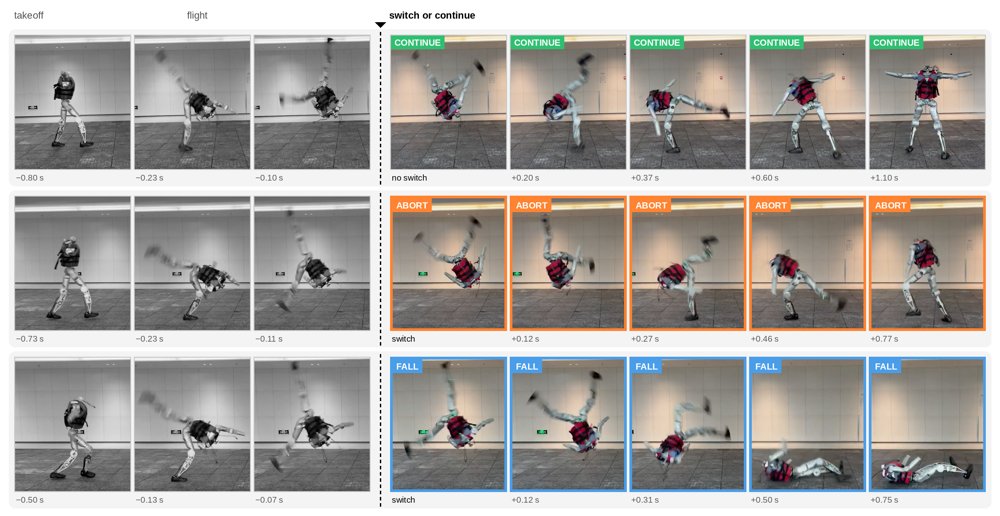
Continue, Abort, or Fall: Viability-Aware Policy Selection (VAPS) for Safe Humanoid Acrobatics
作者:Siwei Ju, Lu Liu, Jan Peters, Oleg Arenz · 单位:This work is part of the Robotics Institute Germany (RIG). This project has been supported by a hardware donation by NVIDIA through the Academic Grant Program., $ˆ1$Department of Computer Science, Technical University of Darmstadt, Germany., $ˆ2$Robotics Institute Germany (RIG)., $ˆ5$German Research Center for AI (DFKI), Research Department: Systems AI for Robot Learning. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-02