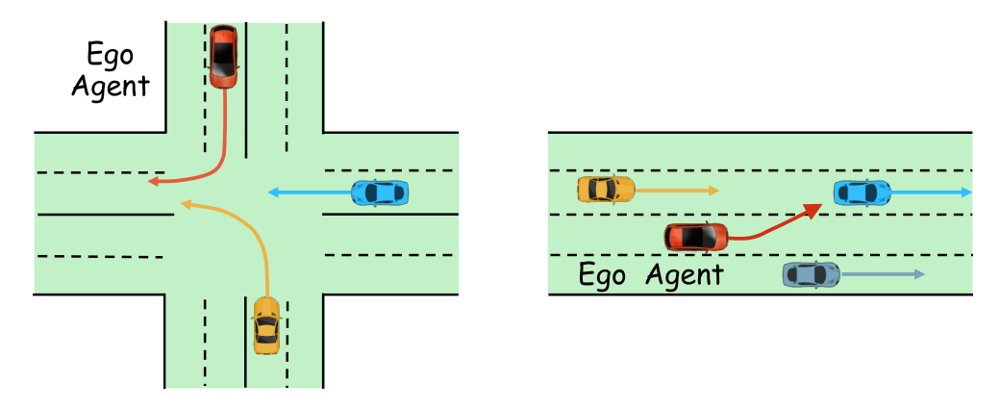
ReWAM: Reciprocal World Action Models for Interactive Autonomous Driving
作者:Benshan Ma, Pei Liu, Ruiguo Zhong, Lang Zhang, Mingyue Feng, Yaonong Wang, Jun Ma · 单位:The Hong Kong University of Science and Technology (Guangzhou), The Hong Kong University of Science and Technology · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-01