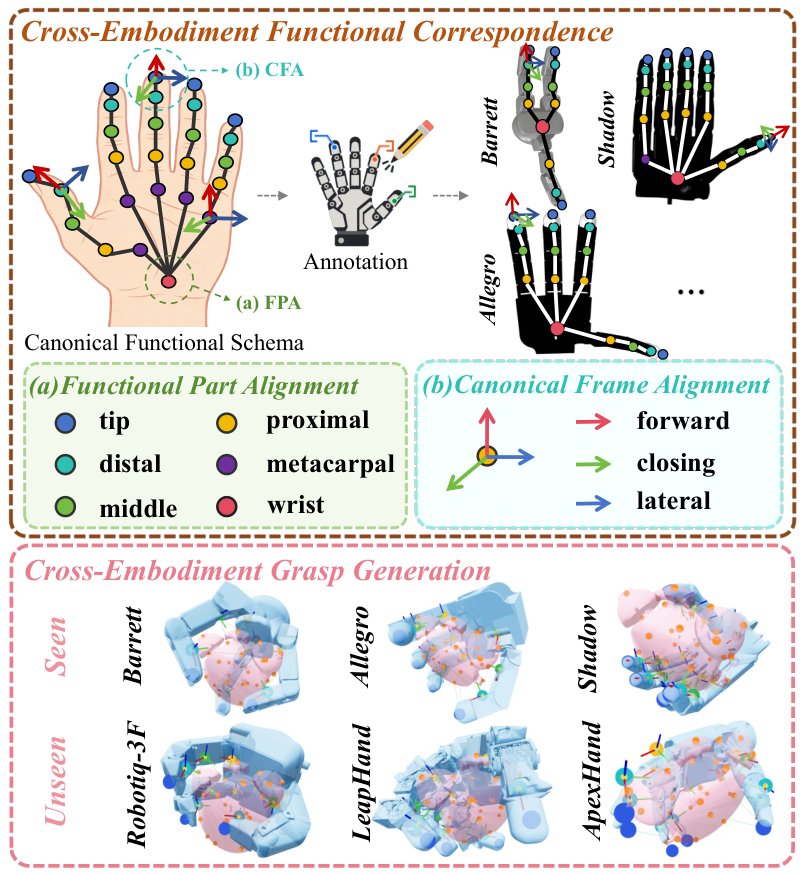
Function beyond Form: Functional Correspondence for Cross-Embodiment Dexterous Grasp Generation
作者:Bolin Zou, Wenlong Dong, Mu Ai, Chao Tang, Aoxiang Gu, Lipeng Chen, Hong Zhang · 单位:Shenzhen Key Laboratory of Robotics and Computer Vision, Southern University of Science and Technology, Shenzhen, China., Department of Robotics, Perception and Learning, KTH Royal Institute of Technology, Stockholm, Sweden., School of Artificial Intelligence, Shanghai Jiao Tong University, Shanghai, China. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-01