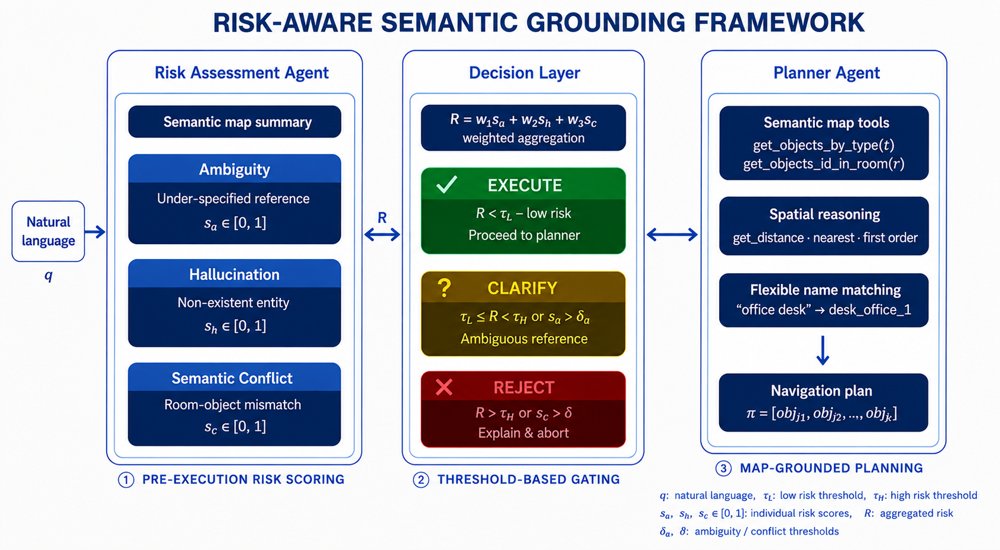
Risk-Aware Semantic Grounding for Trustworthy LLM-Based Robot Planning
作者:Łukasz Sobczak, Nur Keleşoğlu, Sławomir Piotr Nowak · 单位:Institute of Theoretical and Applied Informatics, Polish Academy of Sciences, Gliwice 44-100, Poland · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-30