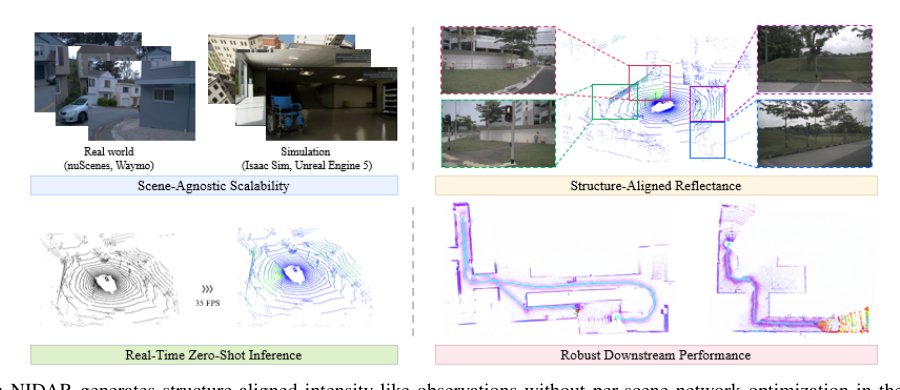
NIDAR: NIR-Guided Intrinsic Decomposition for Scalable Scene-Agnostic LiDAR Intensity Reconstruction
作者:Junjie Zhang, Jie Yin, Kefei Qian, Jie Li, Mengpei Jia, Yajuan Dun, Wenbo Chu, Guofa Li · 单位:NIDAR: NIR-Guided Intrinsic Decomposition for Scalable, labels nor target-scene gradient-based fitting. The reported, robot validation. NIDAR therefore offers a scalable intensity-, Chongqing University, 2Shanghai Jiao Tong University, 3Ministry of In-, Center of Intelligent and Connected Vehicles, ∗Corresponding author, These requirements limit their scalability when many scenes, intrinsic-decomposition framework for scalable LiDAR in-, UNet+DeepLabV3 design. After offline training and source-, CAD scenes, which is labor-intensive and suffers from a, limits their scalability beyond the captured scenes., diffusion models to simulate raydrop and enable controllable, diversity and scalability, their intensity channel is often · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-30