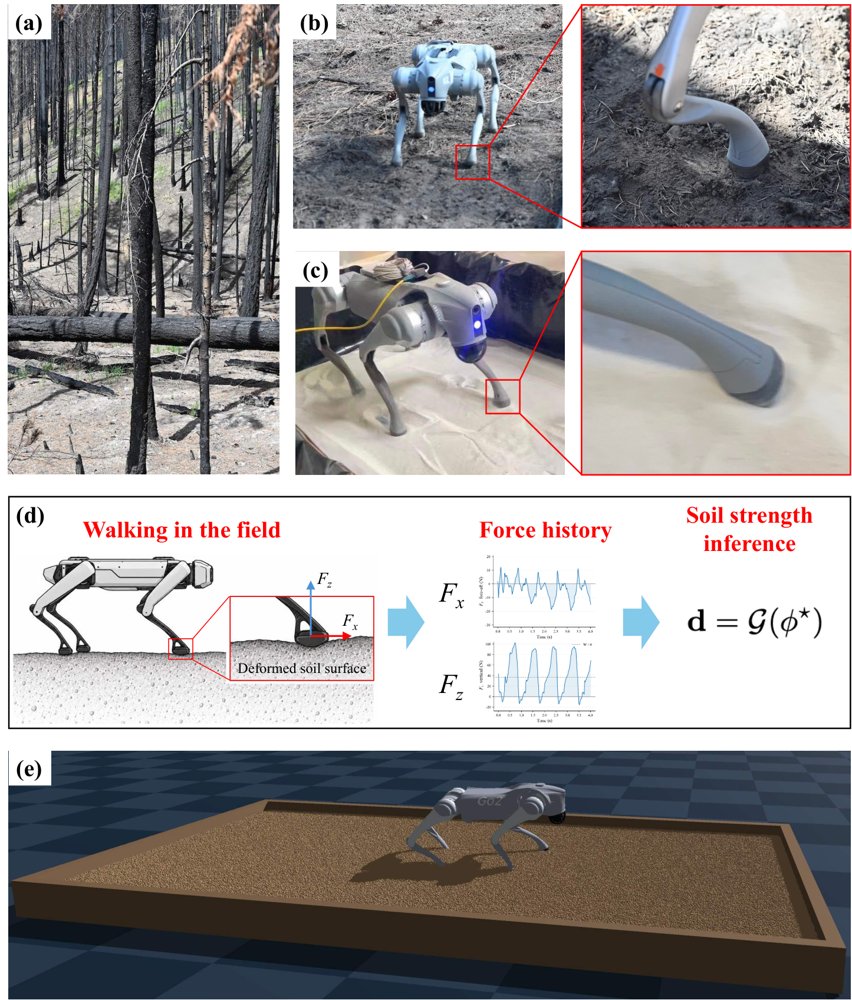
Inferring Soil Friction Angle from Robot Foot-Ground Force Histories: A Bayesian Inverse Approach to Proprioceptive Soil Sensing
作者:Dawei Xu, Zhijie Wang · 单位:Department of Civil and Environmental Engineering, Washington State University · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-30