SkillWeaver: Agentic Exploration over Neural Interaction Skills for Scalable Robot Data Generation
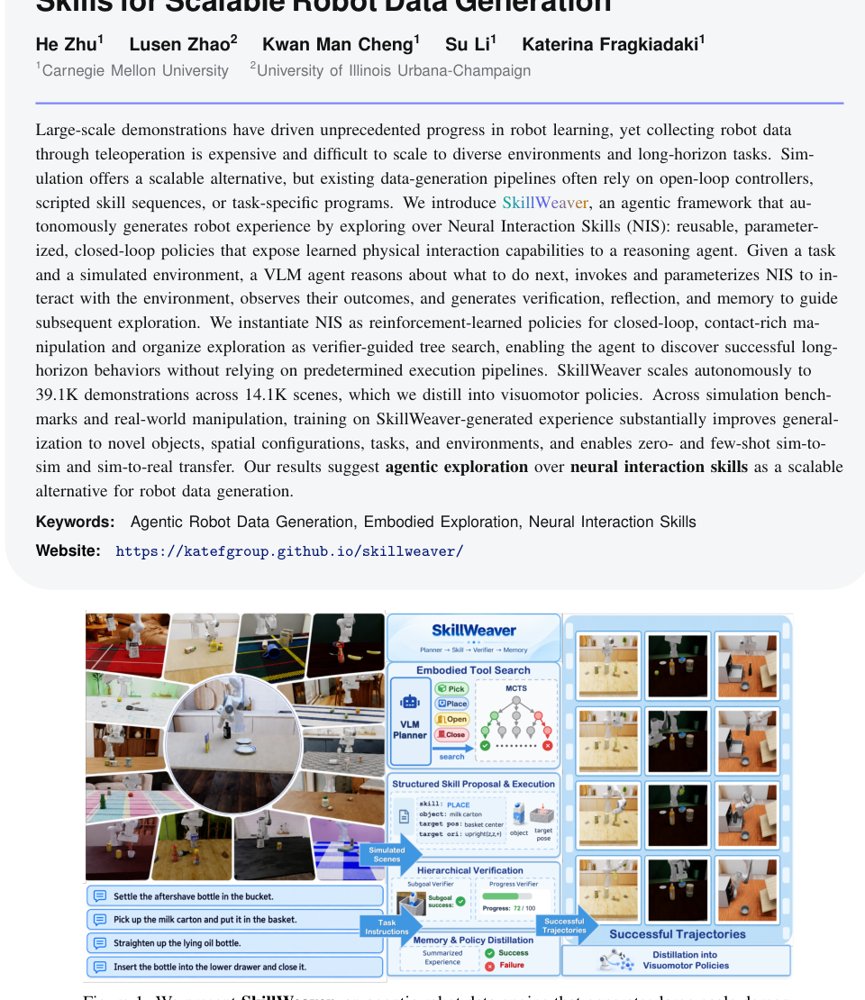
作者:He Zhu, Lusen Zhao, Kwan Man Cheng, Su Li, Katerina Fragkiadaki · 单位:Skills for Scalable Robot Data Generation, Carnegie Mellon University, University of Illinois Urbana-Champaign, ulation offers a scalable alternative, but existing data-generation pipelines often rely on open-loop controllers, sim and sim-to-real transfer. Our results suggest agentic exploration over neural interaction skills as a scalable, Agentic Exploration over Neural Interaction Skills for Scalable Robot Data Generation, data remains a fundamental bottleneck. Collecting high-quality demonstrations is expensive, labor-, generalization remains challenging even for well-resourced laboratories., Simulation offers an appealing alternative: once an interactive environment is available, robot expe-, LLMs and VLMs can reason over available tools, invoke them, observe their outcomes, and itera-, Building on this idea, we present SkillWeaver, an agentic framework for scalable robot data gener-, in which an agent can actively search for its own training experience. Combined with scalable en- · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-30