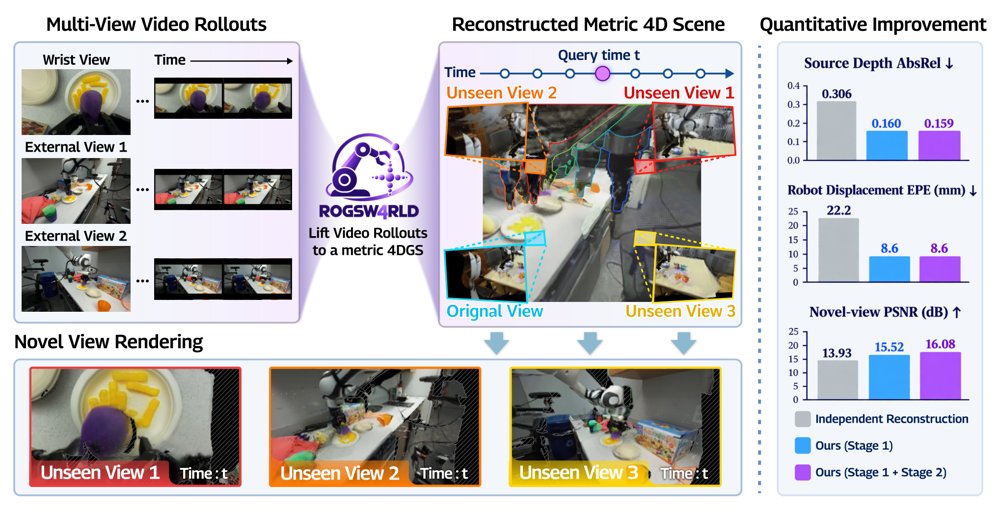
RoGSW4RLD: Feed-Forward 4D Gaussian Lifting for Robot World Model Rollouts
作者:Jin Hyun Kim, Min Young Kim, Soohwan Song, Daekyum Kim · 单位:School of Mechanical Engineering, Korea University, College of AI Convergence, Dongguk University, School of Smart Mobility, Korea UniversitySeoul, Republic of Korea · 会议/期刊:arXiv preprint · 方向:cs.CV · 发布日期:2026-09-29