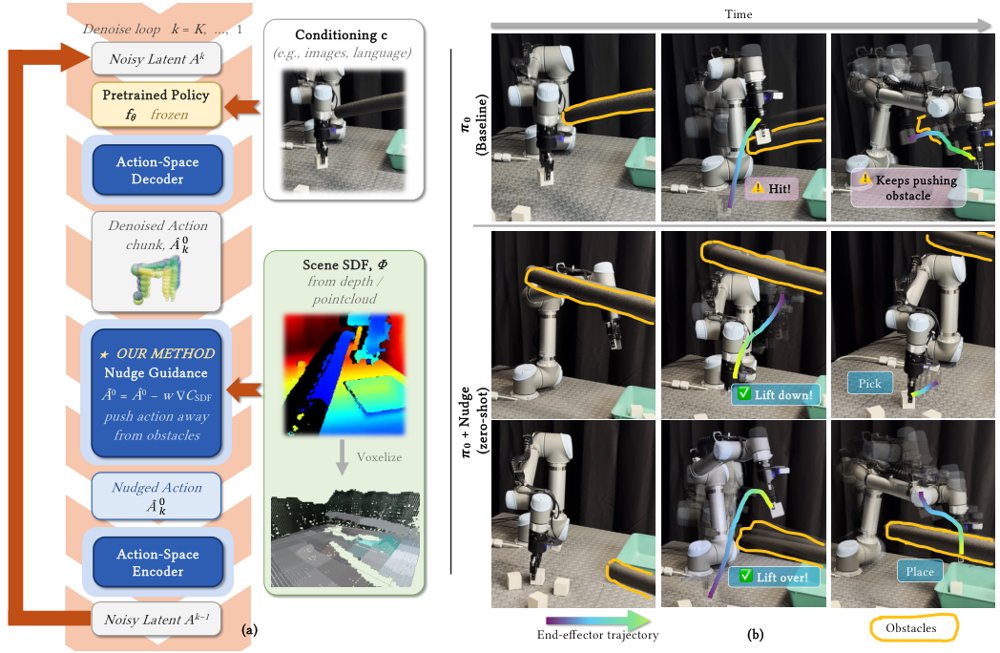
Zero-Shot Reactive Obstacle Avoidance for Generative Robot Policies
作者:Weihang Guo, Lydia E. Kavraki · 单位:† † thanks: The authors are with the Department of Computer Science, Rice University, † † thanks: This work was supported in part by Enrich funds at Rice University. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29