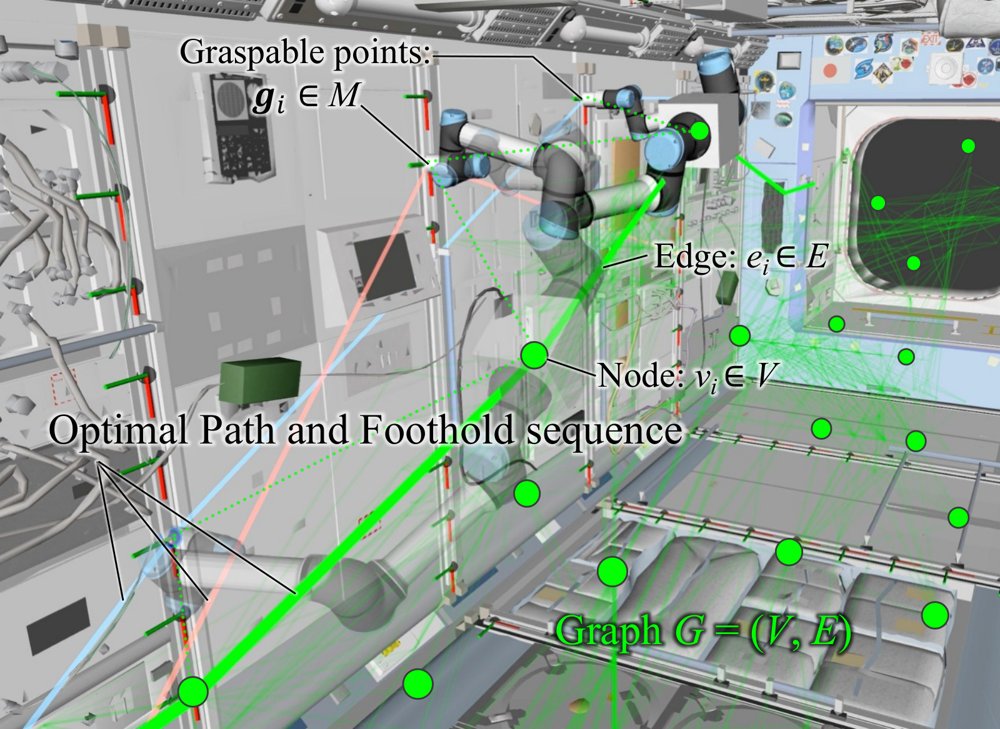
Graph-Based Simultaneous Path and Foothold Planning for Multi-Limbed Intra-Vehicular Robots in Space Stations
作者:Masazumi Imai, Kentaro Uno, Toshinori Kuwahara, Kazuya Yoshida · 单位:M. Imai is with the Department of Aerospace Engineering, Graduate School of Engineering, Tohoku University, Sendai 980-8579, Japan., K. Uno and K. Yoshida are with the New Industry Creation Hatchery Center (NICHe), Tohoku University, Sendai 980-8579, Japan., T. Kuwahara is with the Research Center for Green X-Tech and Research Center for Space Cross-Tech, Green Goals Initiative, Tohoku University, Sendai 980-8579, Japan. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29