主页
返回索引
+
点赞
0
arXiv preprint / cs.RO
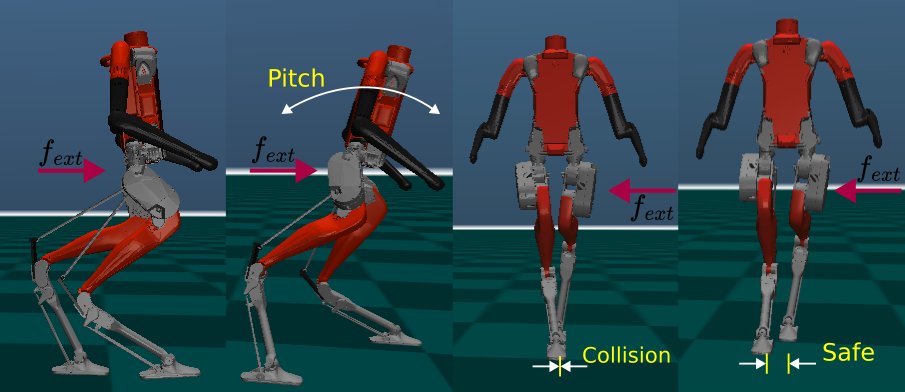
Model-Informed Safe Reinforcement Learning for Bipedal Locomotion via Step-to-Step Prediction
作者:
Victor Paredes, Ayonga Hereid ·
会议/期刊:
arXiv preprint ·
方向:
cs.RO ·
发布日期:
2026-09-29
2026-09-29
🧠 机器人学习
AlphaXiv
精读笔记
新标签打开 AlphaXiv
AlphaXiv 中文概览(可滚动查看)
✦
这篇论文还没有精读笔记
点击后会加入生成队列
生成精读笔记