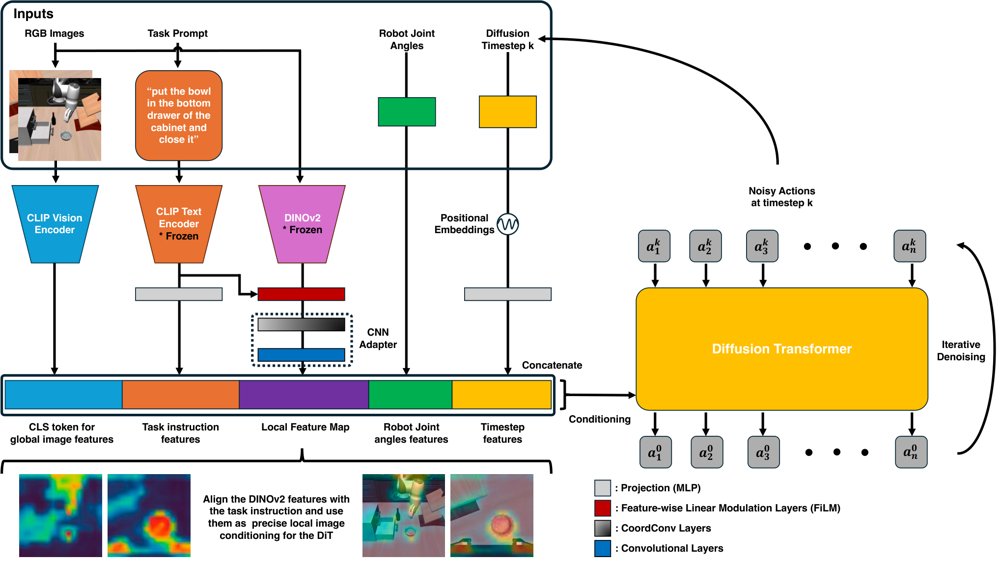
作者:Xianbo Cai, Hideyuki Ichiwara, Zihang Wang, Yijun Lu, Tetsuya Ogata · 单位:Hideyuki Ichiwara is with SB Intuitions Corp., Tokyo, Japan. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29
点击后会加入生成队列