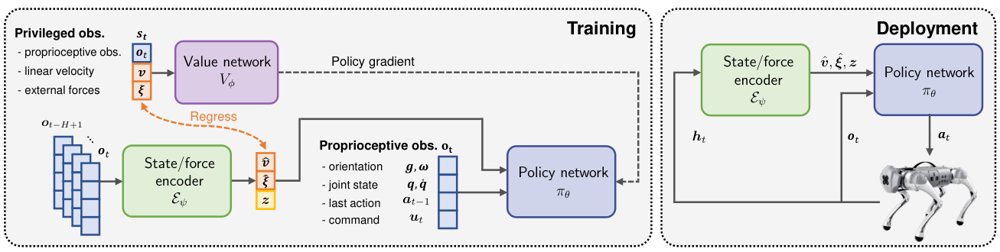
Proprioceptive Force Estimation for Quadruped Locomotion and Human-Robot Interaction
作者:Run Wang, Xu Yang, Alapati Tuerxun, Yilin Mo · 单位:† † thanks: The authors are with the Department of Automation, Tsinghua University, Beijing, China. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29