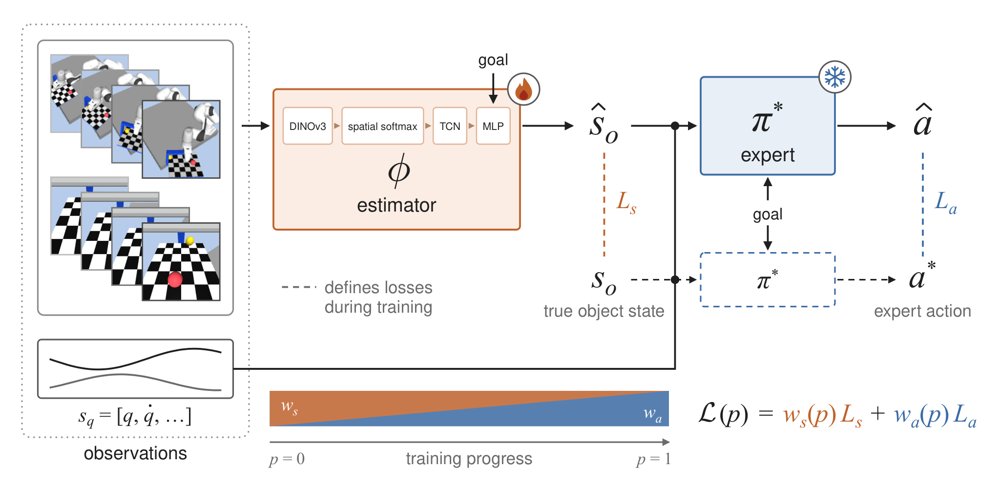
Estimate, Don't Imitate: Reusing Differentiable State-Based Policies for Visuomotor Control
作者:Denis Shcherba, Adrian Abel, Eckart Cobo-Briesewitz, Wojciech Samek, Marc Toussaint · 单位:BIFOLD – Berlin Institute for the Foundations of Learning and Data, Berlin, Germany., Robotics Institute Germany. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29