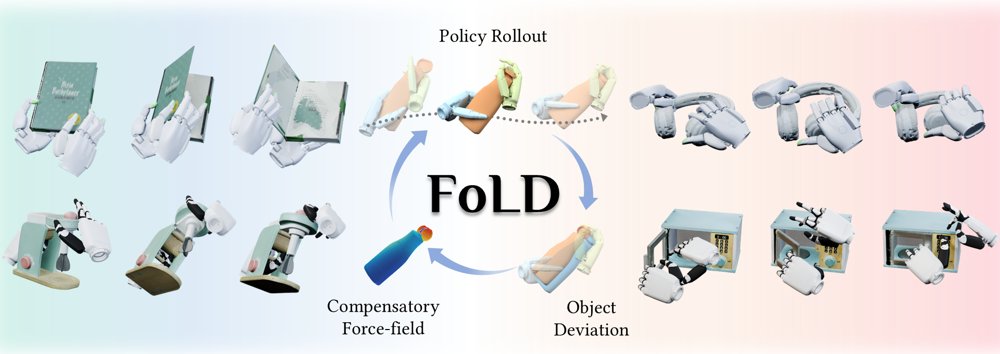
FoLD: Force-Informed Learning for Dexterous Articulated Object Manipulation
作者:Haowei Shen, Tingai Li, Yumeng Liu, Wenyuan Guang, Xuanze Yang, Qing Fang, Kai Xu, Ligang Liu, Ruizhen Hu · 单位:University of Science and Technology of China, Institute of AI for Industries, Chinese Academy of Sciences, Jiangsu Key Laboratory of AI for Industries, Shenzhen University · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29