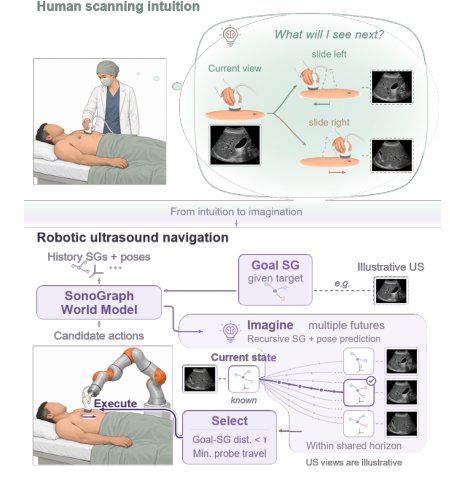
Scanning While Imagining: A Scene-Graph World Model for Robotic Ultrasound Navigation
作者:Xuesong Li, Shuai Chen, Feng Li, Zhongliang Jiang, Nassir Navab, Yuan Bi · 单位:from computed tomography (CT) label maps along surface-, iments with label-map-derived SGs, the planner reached the, a Computer Aided Medical Procedures (CAMP), Technical University, b Munich Center for Machine Learning, c Department of Mechanical Engineering, The, University of Hong Kong, Hong Kong SAR, China., Anatomically labeled CT volumes offer an alternative, planes along generated probe paths using CADS organ label, label maps, reducing the need for tracked and anatom-, mented vessel geometry to maintain centering and perpen- · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29