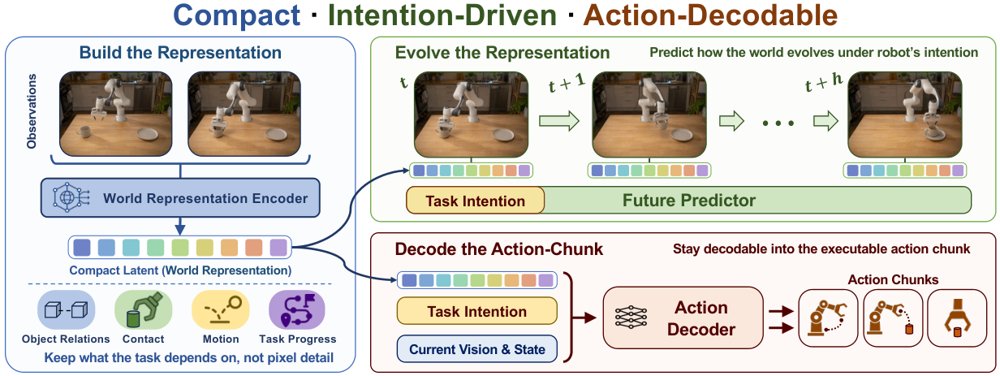
Copper-Policy: Focus on the Representation for Robust Robot Manipulation
作者:Zexin Feng, Yixu Feng, Lingyu Xiao, Shang Su, Kexin Zheng, Chang Xu, Mengkai Shi, Shuo Feng, Xintao Yan · 单位:The University of Hong Kong, The University of Sydney, Tsinghua University, DenseAI Inc. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29