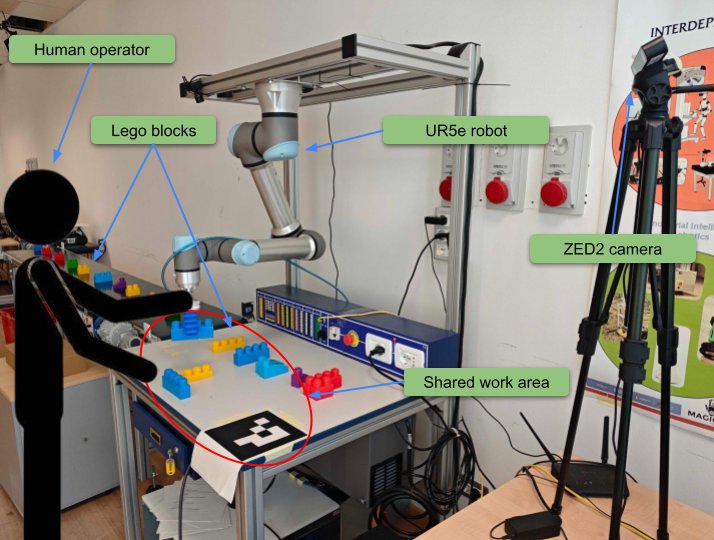
Proactive Motion Planning for Human-Robot Cooperation
作者:Elena Basei, Edoardo Lamon, Matteo Saveriano, Daniele Fontanelli, Luigi Palopoli · 单位:Department of Information Engineering and Computer Science, Università di Trento, Trento, Italy., Department of Industrial Engineering, Università di Trento, Trento, Italy. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-29