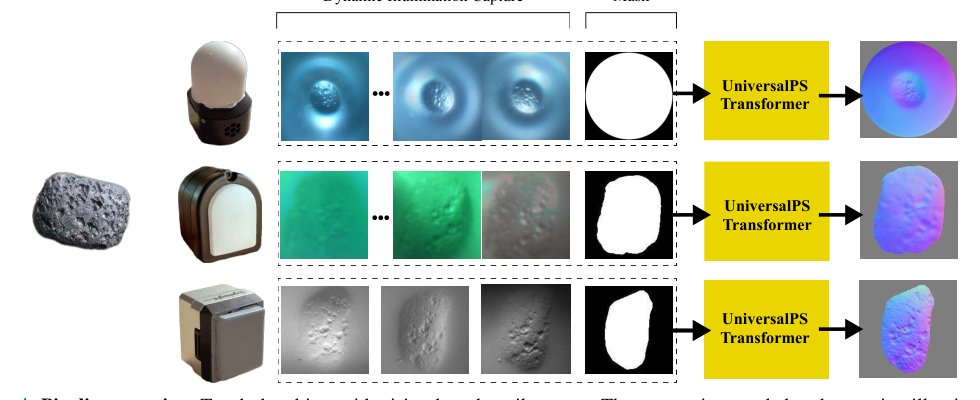
Calibration-Free Surface Normals Estimation in Vision-Based Tactile Sensing using Universal Photometric Stereo
作者:Zdravko Dugonjic, Stefanie Speidel, Roberto Calandra · 单位:LASR Lab, TU Dresden, Germany, Centre for Tactile Internet with Human-in-the-Loop (CeTI), Technis-, Department of Translational Surgical Oncology, National Center, for Tumor Diseases (NCT), a partnership between DKFZ, University, Hospital Carl Gustav Carus, TUD Dresden University of Technology, and, avoid laborious sensor probing [10] used sim-to-real approach, [31], [32] without requiring expensive equipment or laborious · 会议/期刊:arXiv preprint · 方向:cs.CV · 发布日期:2026-09-29