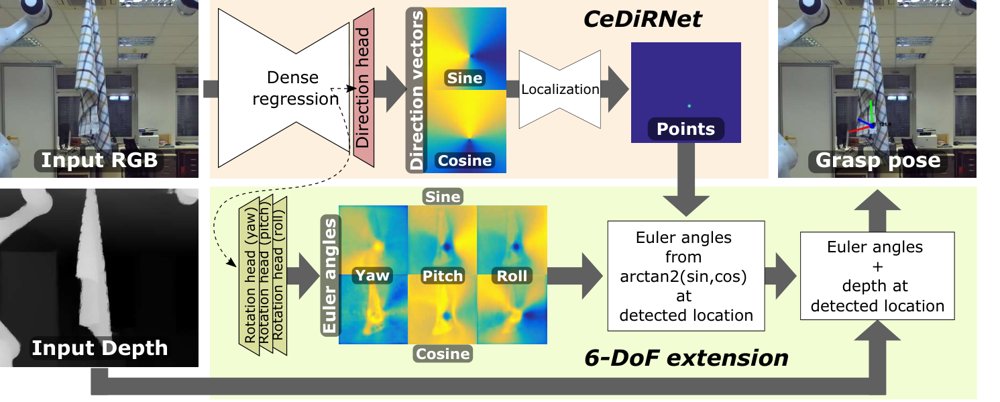
Vision-Based 6-DoF Grasp Pose Estimation for Robot Cloth Unfolding
作者:Domen Tabernik, Peter Nimac, Jan Jerićević, Danijel Skočaj, Andrej Gams · 单位:Faculty of Computer and Information Science, University of Ljubljana, Večna pot 113, 1000 Ljubljana, Slovenia, Jožef Stefan International Postgraduate School, Jamova cesta 39, 1000 Ljubljana, Slovenia, Jožef Stefan Institute, Jamova cesta 39, 1000 Ljubljana, Slovenia · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-28