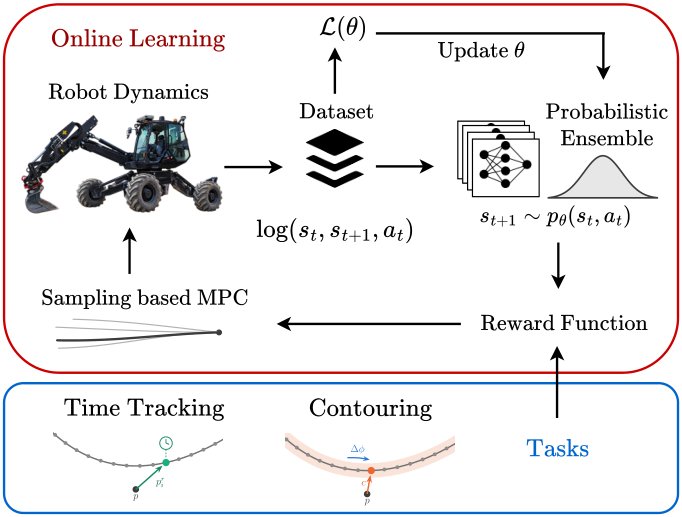
Precision at Speed: Sample-Efficient Online Model-Based Reinforcement Learning for Hydraulic Excavator Control
作者:Claudio Canales, Fang Nan, Marco Hutter, Javier Ruiz-del-Solar · 单位:The authors are with the Robotic Systems Lab, ETH Zürich, 8092 Zürich, Switzerland., The authors are with the Advanced Mining Technology Center (AMTC) and the Department of Electrical Engineering, Universidad de Chile, Santiago, Chile. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-28