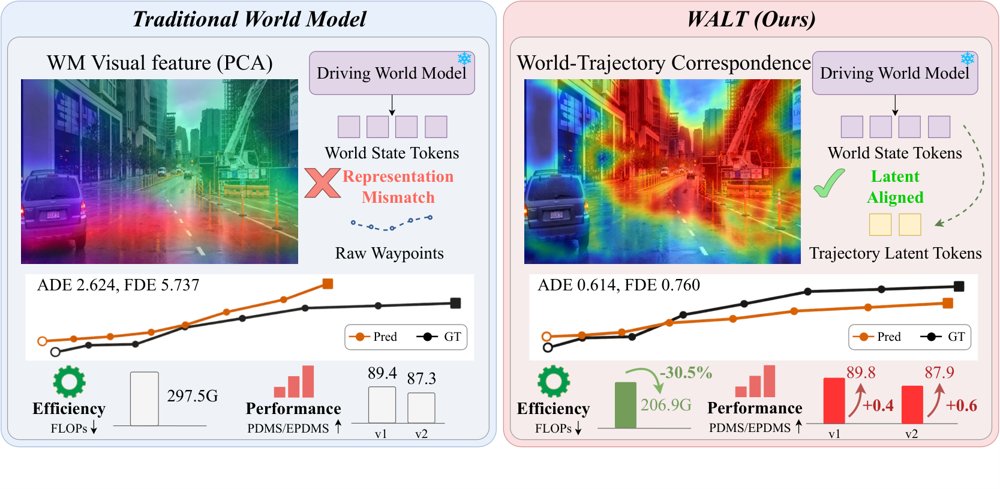
WALT: Learning World-Model-Aligned Latent Trajectories for Autonomous Driving
作者:Mingkai Jia, Jiaxin Guo, Zhijian Shu, Jiawei Xu, Mingxiao Li, Jintao Cheng, Ping Tan, Wei Yin · 单位:The Hong Kong University of Science and Technology., The Chinese University of Hong Kong., Nanjing University of Posts and Telecommunications., Nankai University. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-28