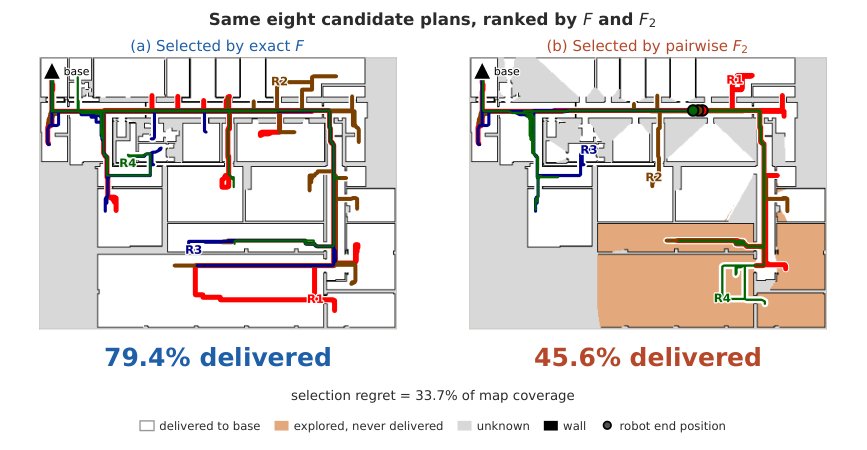
Pairwise Approximation Can Select the Wrong Multi-Robot Plan
作者:William Teo · 单位:MARMoT Lab, Department of Mechanical Engineering, National University of Singapore, NEAR Lab, AI.Robotics Strategic Technology Centre, Singapore Technologies Engineering · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-25