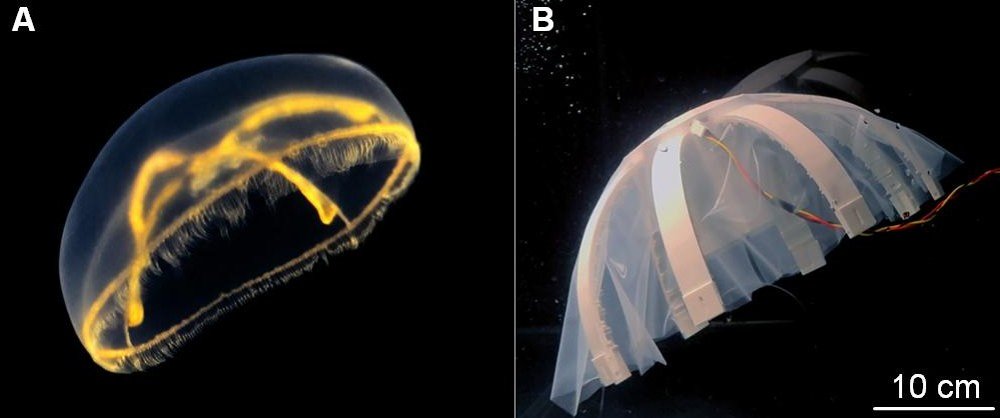
A Tendon-Driven Robotic Jellyfish with Constrained Soft Actuation and Depth Control via Reinforcement Learning
作者:Jiarui Peng, Yutong Wu, Zelong Wang, Ping Deng, Xiaotian Zhang, Xian Chen, Kecheng Qin, Zhongyi Li · 单位:Hong Kong Embodied AI Lab, Hong Kong SAR, China, The Chinese University of Hong Kong, Hong Kong SAR, China, The Hong Kong University of Science and Technology, Hong Kong SAR, China · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-25