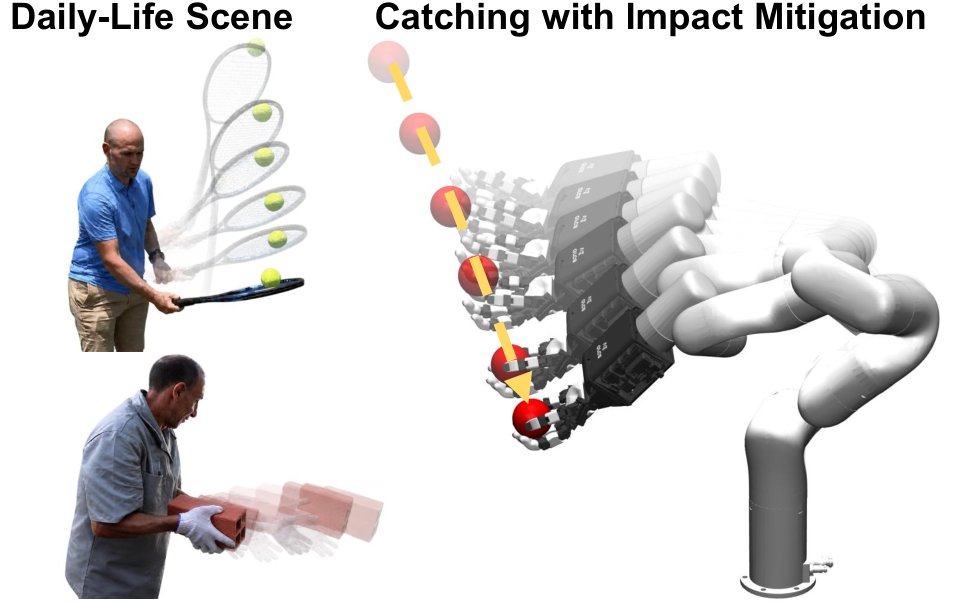
Outcome-Sensitive Motion Search for Impact-Aware Dexterous Catching
作者:Guorui Pei, Jinsong Wu, Songyuan Su, Jiaming Qi, Sichao Liu, David Navarro-Alarcon, Bin Liu, Peng Zhou · 单位:College of Robotics Science and Engineering, Taiyuan University of Technology, Taiyuan, China, Department of Mechanical Engineering, The Hong Kong Polytechnic University, Kowloon, Hong Kong SAR, China, Southern University of Science and Technology, Shenzhen, China, School of Advanced Engineering, Great Bay University, Dongguan, Guangdong, China, College of Mechanical and Electrical Engineering, Northeast Forestry University, Harbin, China, Department of Production Engineering, KTH Royal Institute of Technology, Stockholm, Sweden, Kaiyang Laboratory, Chery Automobile Co., Ltd., Wuhu, Anhui, China * Corresponding authors. · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-09-25