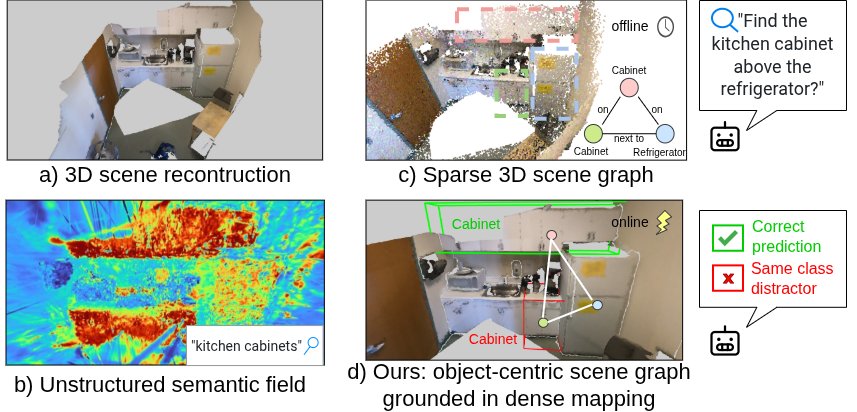
OpenSplatGraph: From Dense Semantic Maps to Structured Scene Graphs for Open-Vocabulary Robot Perception
作者:Binh Long Nguyen, Kien Nguyen, Clinton Fookes, Peyman Moghadam · 单位:School of Electrical Engineering and Robotics, Queensland University of Technology (QUT), Brisbane, QLD 4000, Australia · 会议/期刊:arXiv preprint · 方向:cs.RO · 发布日期:2026-10-07